


Reaching into the box
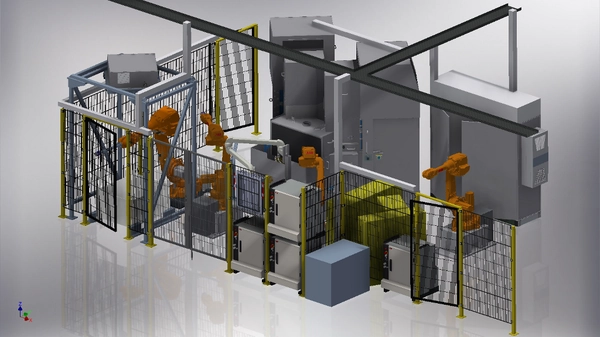
A camera system with high-resolution cameras – in this case from Keyence – detects the position of the workpieces, which are lying disorderly in a mesh box or shepherd’s crate, and passes this information on to the handling robot.
- Provision and feeding of disordered workpieces with bin-picking from two KLT boxes
- Docking stations for KLT containers with repeatable positioning via stops
- Bin-picking robot ABB
- Double gripper with two magnetic grippers with adjustable magnetic force for removing workpieces from KLT box
- 3D robot vision
- Camera-controlled turning and centering station
- 3D position detection via camera measuring system with high-resolution cameras
- Automatic calculation of the optimum robot path
- Special robot gripper depending on the workpiece
- Loading robot with adjustable magnetic force for loading and unloading the sanding machine and loading the cleaning and drying station